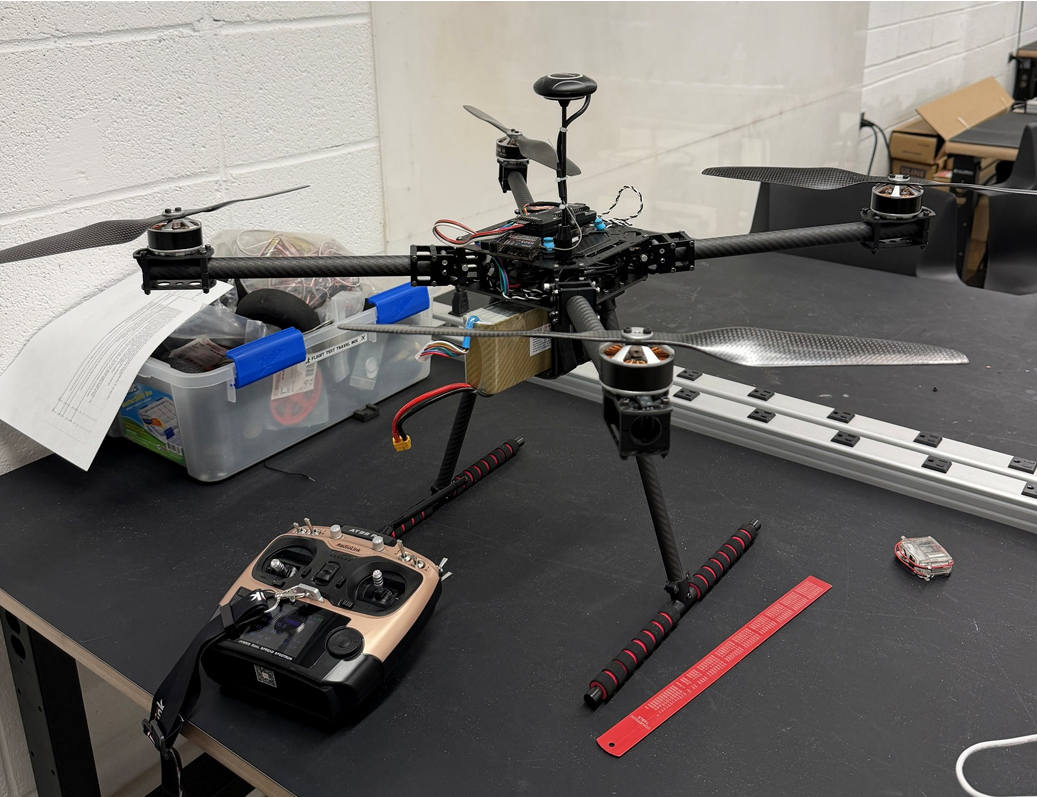
 01
Aerial robotics · In progress
Pressure-Washing Drone
An ongoing aerial cleaning platform integrating flight control, Raspberry Pi computing, camera and LiDAR sensing, washer actuation, and fluid delivery.
Project contents
A collection of work across autonomous navigation, aerial robotics, rover development, legged robotics, embedded systems, controls, and computational modeling. Select a project to open its complete case study.
Selected systems
Each project documents the problem, system architecture, implementation, engineering decisions, testing process, current limitations, and results.
01
Aerial robotics · In progress
An ongoing aerial cleaning platform integrating flight control, Raspberry Pi computing, camera and LiDAR sensing, washer actuation, and fluid delivery.
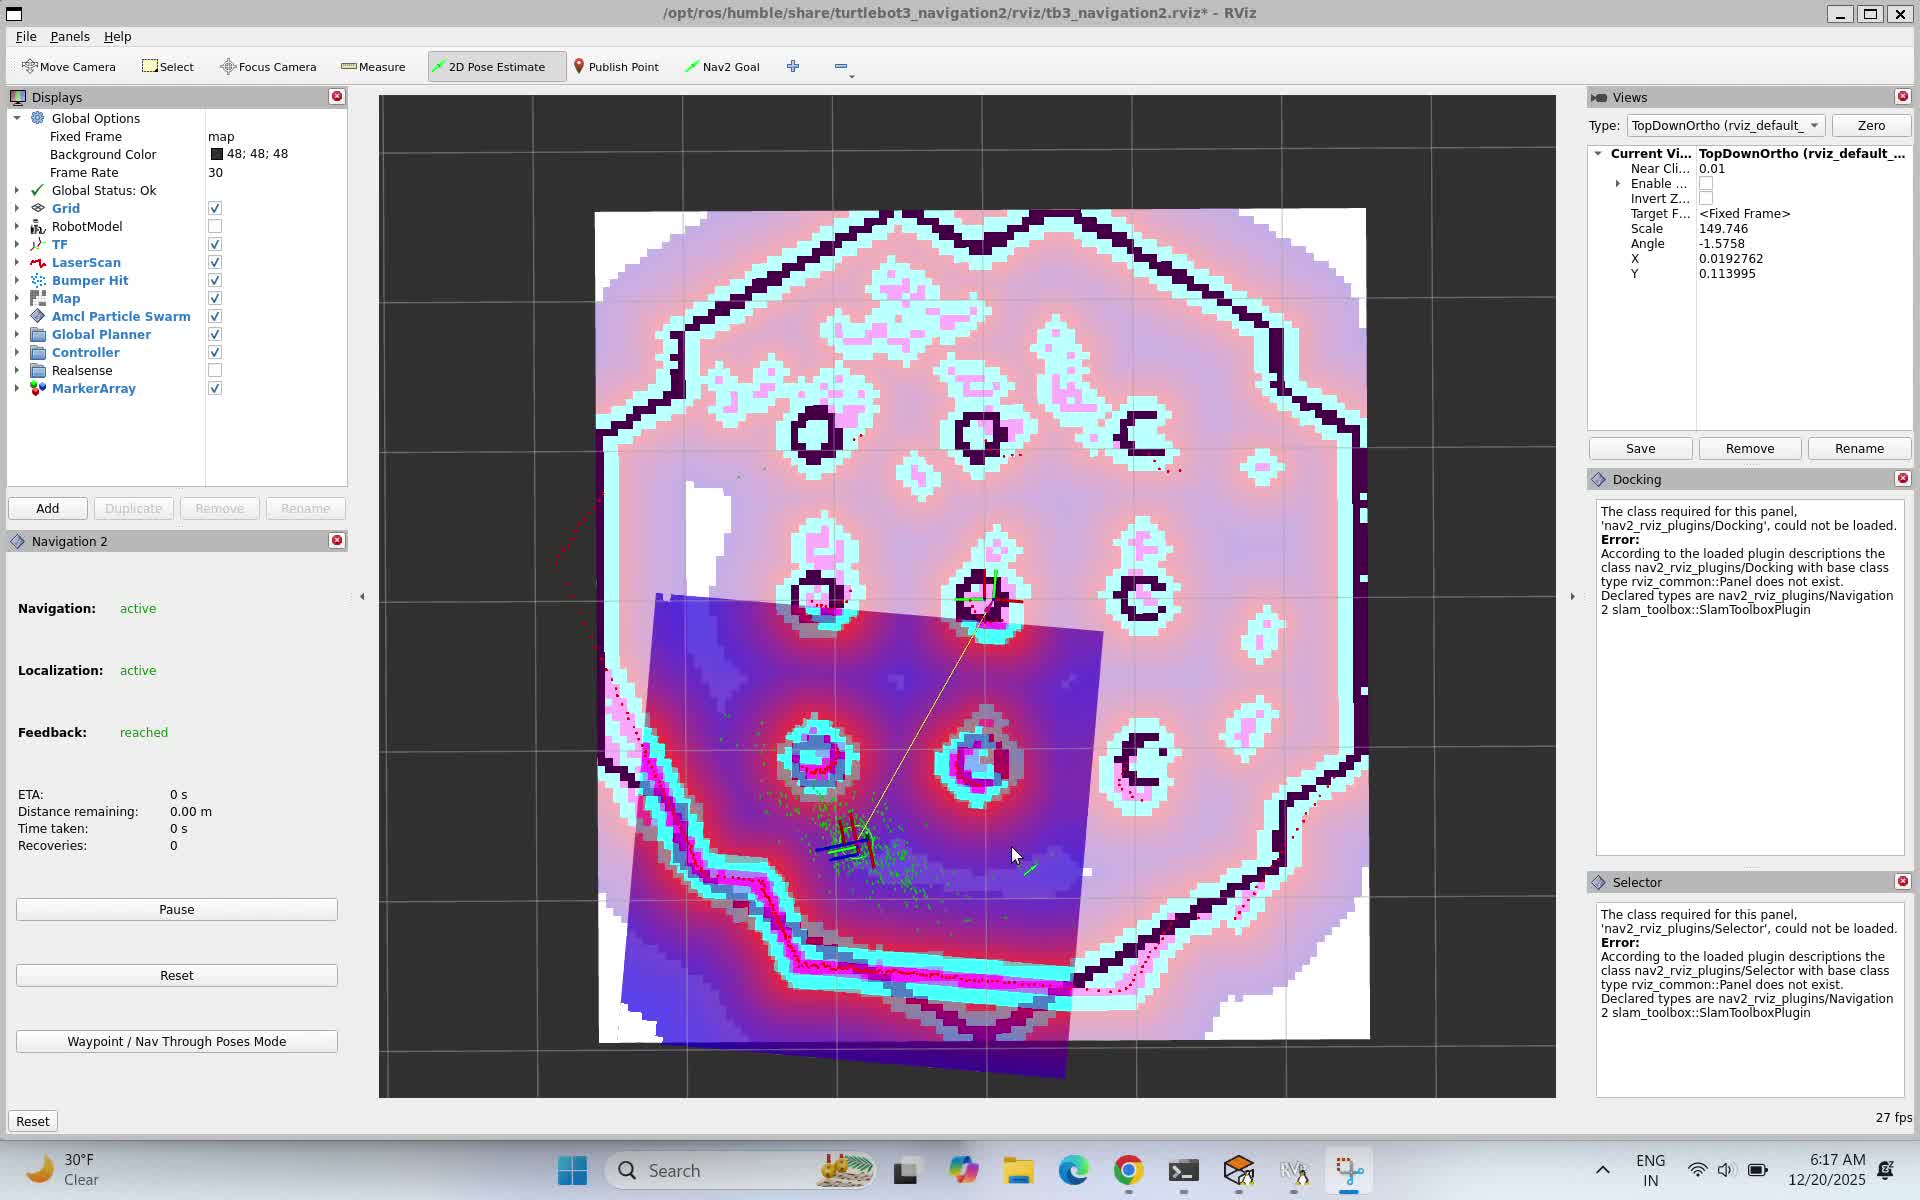 02
Autonomous navigation · Simulation
Autonomous waypoint patrol using Nav2, AMCL, dynamic replanning, recovery behavior, and logged navigation metrics.
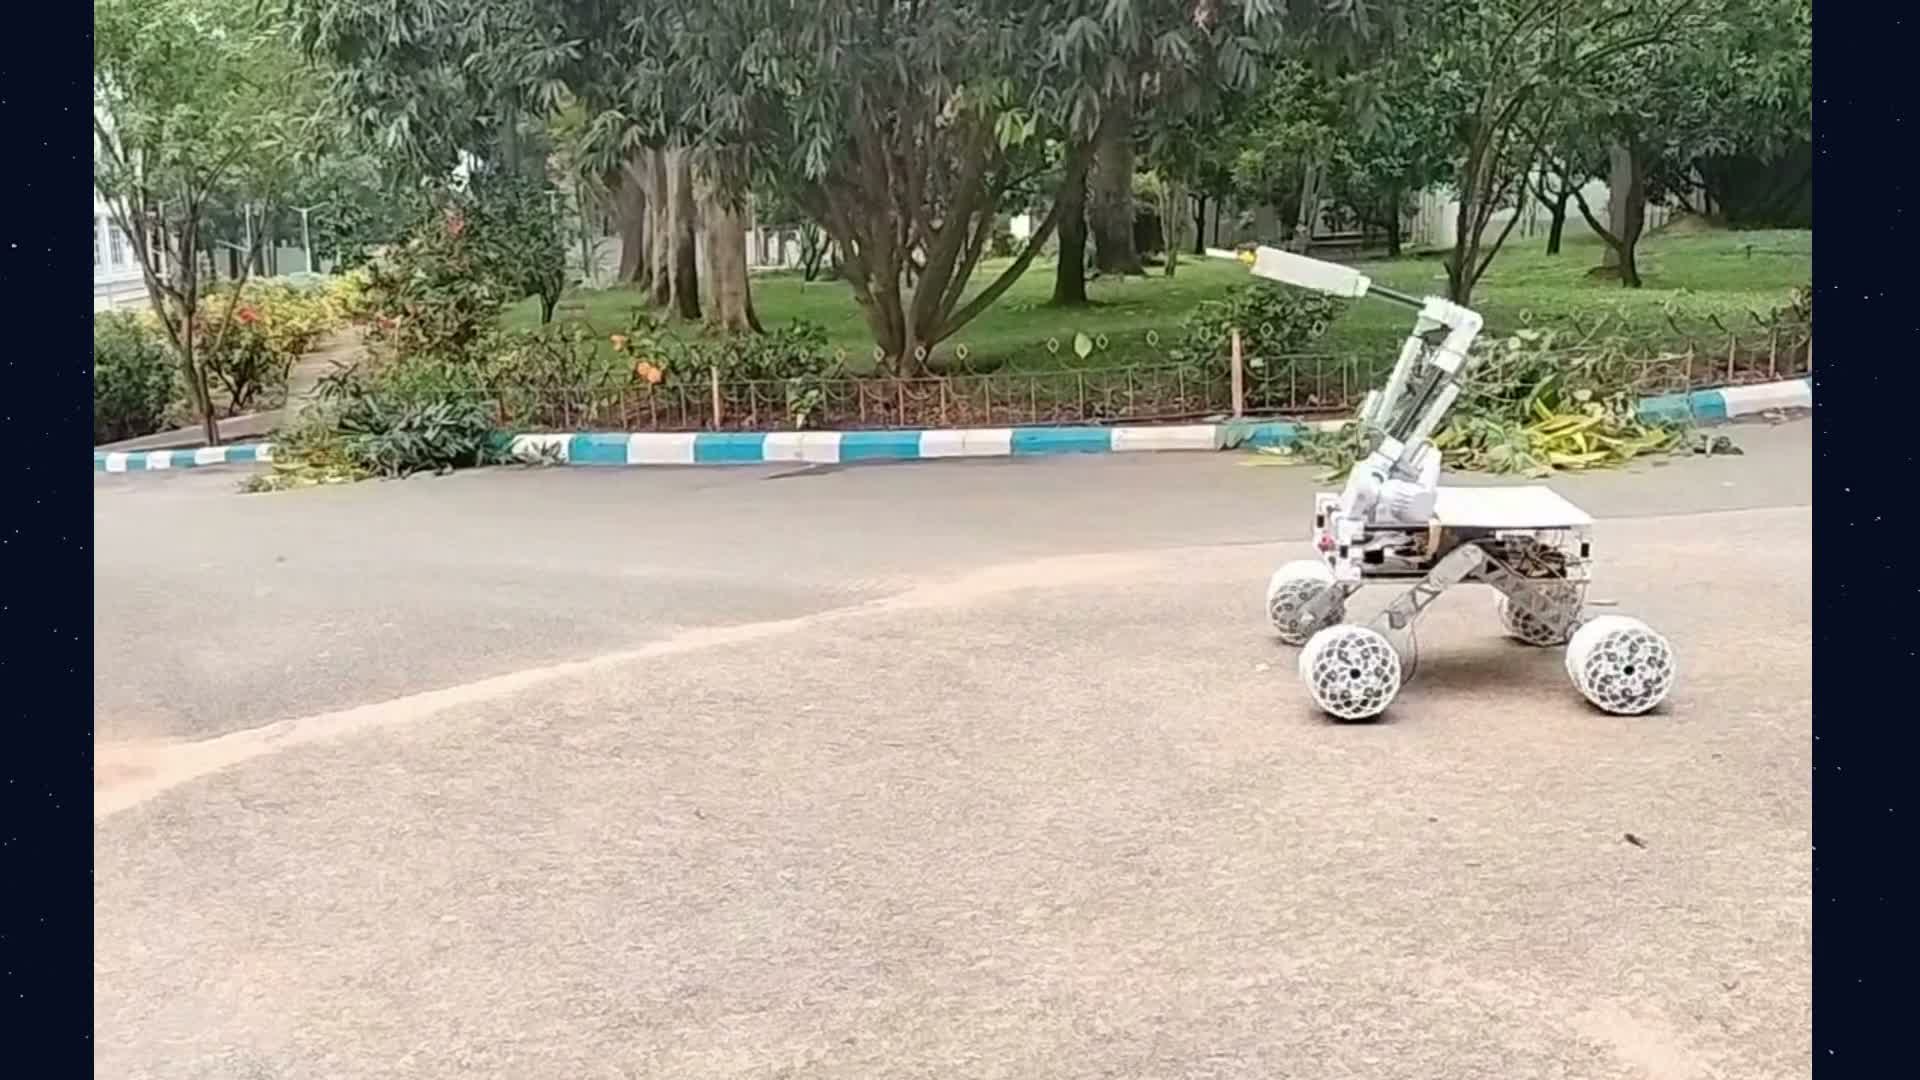 03
Rover engineering · Team Odyssey
A multidisciplinary rover integrating mobility, perception, manipulation, embedded control, power distribution, and emergency response.
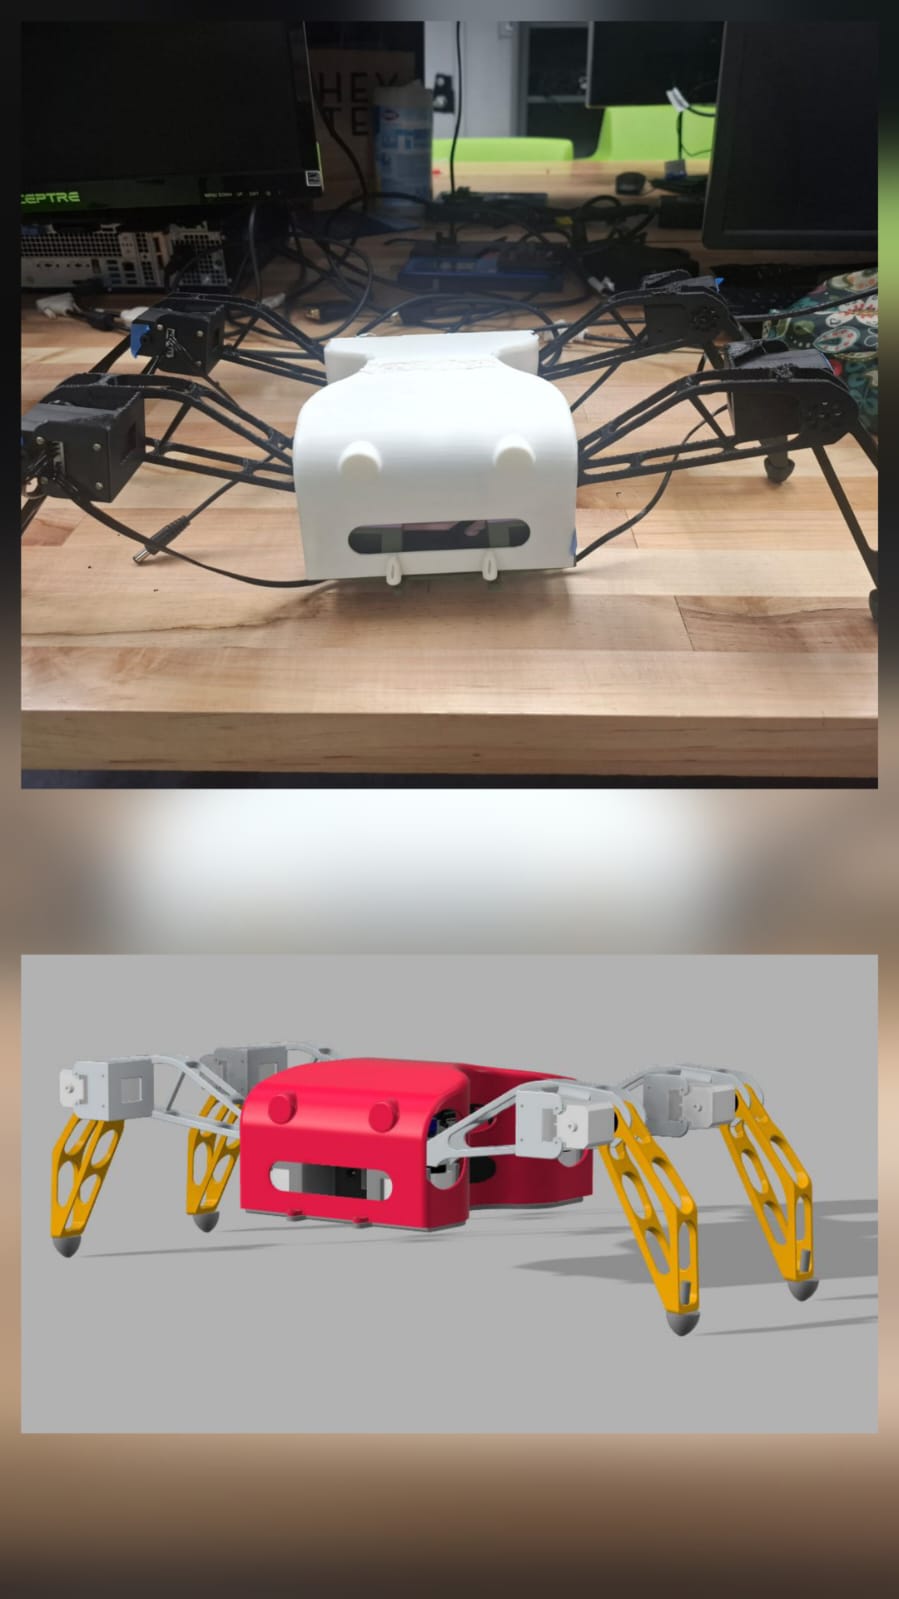 04
Embedded control · Hardware
An eight-servo physical platform for gait timing, mechanical design, embedded control, and hardware experimentation.
.jpeg) 05
Computational imaging · Research
Physics-informed longitudinal brain registration using Neural ODEs, segmentation labels, signed distance fields, and deformation analysis.